Banana Box is a community FIRST Tech Challenge team of eight students from Windham, North Andover, and Phillips Academy. We design, build, and program competitive robots for the DECODE season — and we work to share FIRST with as many people as we can, from mentoring rookie teams to running events that have reached over 21,000 people.
Season archive
DECODE
2025–2026
15 Community Events
21K+ People Reached
120+ Volunteer Hours
4 Robot Iterations
Who we were
The DECODE team.
Season roster
-

Rayhan Riaz
Team Captain, Main Driver
-

Stefan Barbu
Lead Scout, Mechanic
-

Ethan Deandrea
Lead Programmer, Second Driver
-

Kiaan Mehta
Programmer, Drive Coach
-

Govind Valiyodiyil
Vice-Captain, Lead Designer
-

Matthew Dona
-

Aditya Biju
Lead Mechanic, Co-Human Player
-

Pranav Mantena
Outreach, Human Player
Robot & engineering
Bumblebee
Design
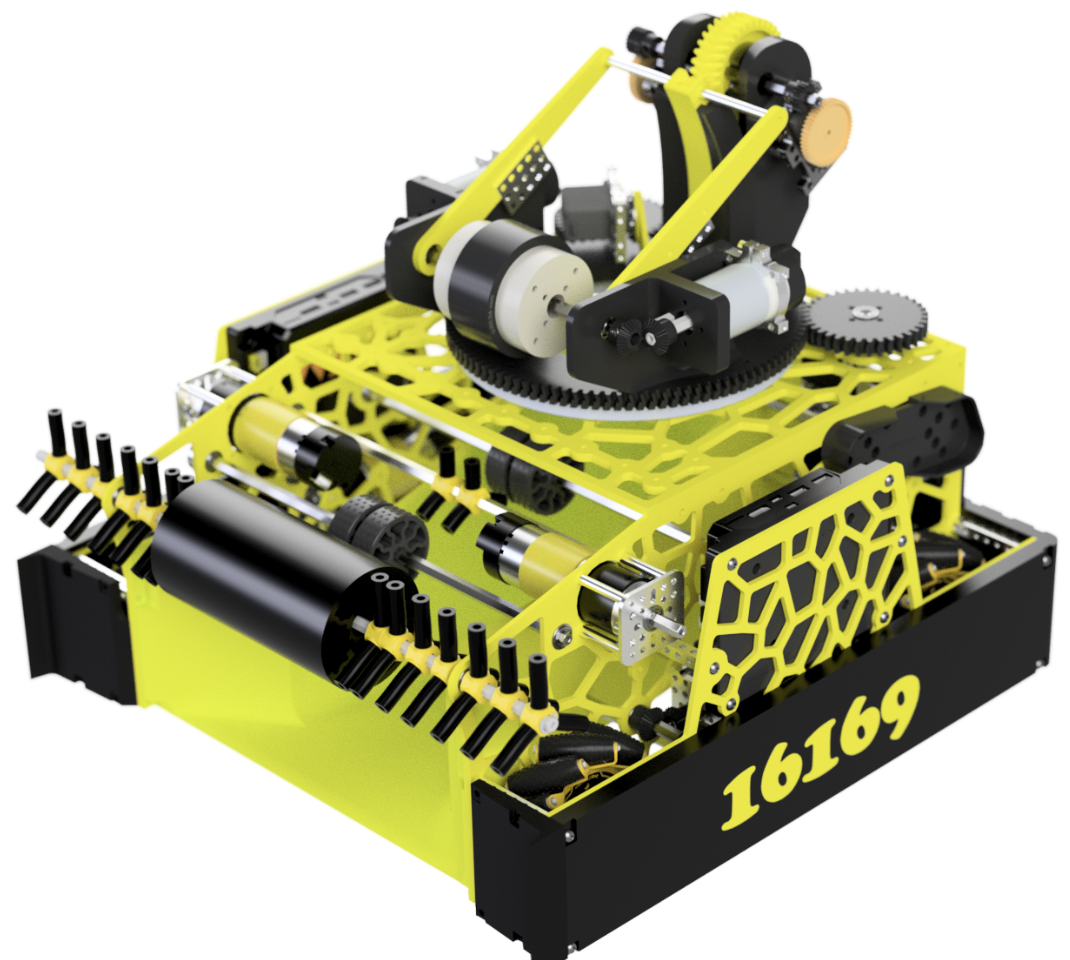
Our robot for the DECODE season, Bumblebee (ARCHEOBOT XYZ), is the fourth iteration in a season of constant refinement — each build measurably better than the last.
Drivetrain. We moved beyond our usual configuration to a belt-driven drivetrain: two 312 RPM goBILDA motors in the back drive 104 mm GripForce mecanum wheels up front. After discovering at the State Championship that heavier motors left us underpowered, we stripped the robot down relentlessly — the final drivetrain weighs just 4.1 pounds total, which keeps us fast and lets us take full advantage of Pedro Pathing’s predictive braking. Our side plates evolved across generations from PLA to aluminum to a custom stainless steel drivetrain for a stronger, more defensive robot.
Turret & launcher. A rotating turret powered by a 6000 RPM motor lets us shoot from different angles and distances. The turret carries a hood that automatically adjusts the flight path by distance, eight goBILDA steel flywheels that hold inertia for rapid-fire shooting, and a gate that shortens the path between artifact and flywheel. We settled on a 30–50° launch angle to cut backspin and shoot accurately.
Intake. Across three generations our intake went from heavy and narrow to a lightweight design using surgical tubing on the ends with gecko wheels in the middle. Funnels with a sharp-then-shallow angle pull artifacts out of corners and line up three at a time.
Endgame & durability. A kickstand raises the part of the robot that sits outside the parking zone, maximizing our endgame score. Absorbent bumpers protect the chassis and odometry after a hard collision dented an earlier build.
Strategy
Autonomous. We score our 3-artifact preload, then the 9 artifacts on the field plus more from the gate — 18+ artifacts — before parking, all inside the 30-second window.
TeleOp. Depending on our alliance we run one of two plans: collect from across the field and the human player and strafe to shoot from the far zone, or cycle quickly through the close launching zone. In both, we use our size and strength to play controlled defense. We favor rapid-fire shooting over spindexers, which we’ve found slower and less reliable to maintain during qualifiers.
Endgame. In the final 20 seconds we keep scoring, then in the last 5 seconds park half the robot inside the zone and use the kickstand for the rest.
Programming
We program in Java in Android Studio, organized into reusable subsystems (turret, intake/transfer, drivetrain) shared between our autonomous and TeleOp — the standard architecture used across FTC. Autonomous paths run on Pedro Pathing, an open-source pathing library whose predictive braking lets the robot slow down and travel faster.
Our turret aiming math computes the distance to the goal, predicts where an artifact will land while the robot is moving, solves for the turret angle, and looks up the right hood angle from an interpolation table — letting us shoot accurately on the move.
Beta testing
During DECODE, thanks to mentor Danny Diaz and our experience with the then-current Control Hub, we were selected from thousands of teams worldwide to alpha/beta test FIRST's next-generation control system: the SystemCore and MotionCore, along with the A301 actuator. As we built expertise with the new system, we shared what we learned across the FIRST community.
Follow the work in the SystemCore Testing GitHub repository .
Robot timeline
DECODE, month by month.
- April 2025
EngineeringCAD refreshers
ProgrammingJava programming refreshers
- June–August 2025
EngineeringBelt-system drivetrain and team development
ProgrammingLimelight learning
- September–October 2025
EngineeringStudied DECODE, prototyped intakes and launchers, and built ARCHEOBOT X.
ProgrammingResearched Pedro Pathing.
- November–December 2025
EngineeringBuilt ARCHEOBOT Y, competed at Qualifier #1, and qualified for the State Championship.
ProgrammingImplemented our pathing software.
- January–February 2026
EngineeringBuilt ARCHEOBOT Z, competed at the State Championship, and qualified for the FIRST World Championship.
ProgrammingImplemented turret PID.
- March–April 2026
EngineeringDesigned a full rebuild, finished the ARCHEOBOT XYZ (Bumblebee) CAD, and prototyped the final turret.
ProgrammingProgrammed shooting on the move.
- May 2026
EngineeringPrepared for the NH FIRST Spring Scramble.
Outreach & impact
DECODE Outreach
During DECODE, we completed 15 community outreach events, two international outreach efforts, and a community service project — over 120 volunteer hours reaching more than 21,000 people.
-
Plaistow Public Library & Londonderry YMCA
We introduced FLL and FTC through hands-on game challenges, robot soccer, and presentations for children, parents, and professionals. Our work with the Londonderry YMCA also helped form and mentor six FLL Challenge and Explore teams.
- 105 Participants
-
Thunder Over NH Airshow
We demonstrated our robots and taught children and adults to drive them at the airshow.
- 20K+ Attendees Reached
-
Wicked STEM Festival
We shared the only scoring robot in the FTC booth, along with a robot dog that helped draw children and professionals into conversations about FIRST.
-
MIT Undergraduate Research Technology Conference
We showcased our robots to undergraduates and professors from around the world, connected with FIRST alumni, and sharpened our presentation skills.
-
NH FIRST Scrimmage #2
We hosted the scrimmage at Windham Center School and served in roles ranging from field inspection to emceeing.
-
NH FTC Qualifier #5
We hosted the qualifier at Windham Center School and supported the event in roles ranging from field inspection to emceeing.
- 26 Teams
-
Team Mentoring & Formation
We mentored teams and helped form new FTC and FLL teams.
-
Community Snow-Shoveling Service
We organized a snow-shoveling service to help neighbors in our community.
Recognition
DECODE awards.
- December 20, 2025
Inspire Award 2nd Place
Bedford Qualifier #1
FTC's top judged award, recognizing an all-around strong ambassador for FIRST.
- January 24, 2026
Inspire Award
Merrimack Qualifier #4
FTC's top judged award, recognizing an all-around strong ambassador for FIRST.
- February 21, 2026
Control Award
NH State Championship
Recognizes innovative use of sensors and software to control the robot.
- February 21, 2026
Advanced to the FIRST Championship
FIRST Championship
Qualified to represent New Hampshire at the FIRST World Championship.
- May 2, 2026
Connect Award 3rd Place
FIRST Championship
Given to the team that most effectively connects with their local STEM and engineering community